Flexible Positioning
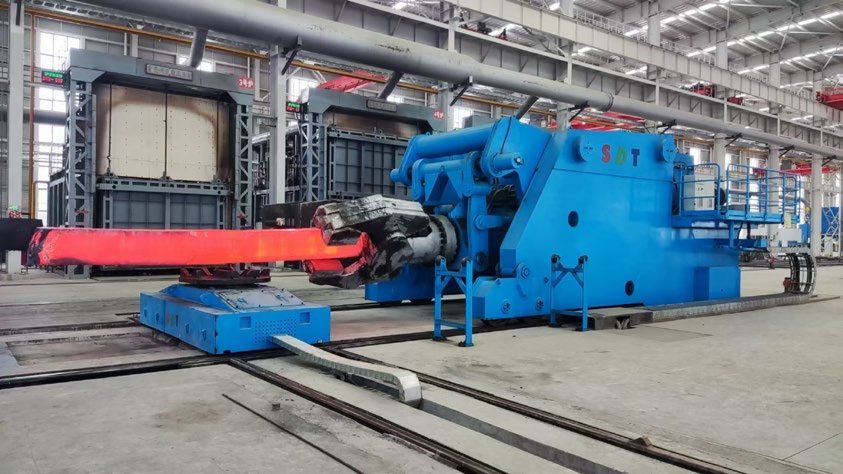
Self-propelled movement supports projects with changing operating positions and routes.
 Discuss Your Project
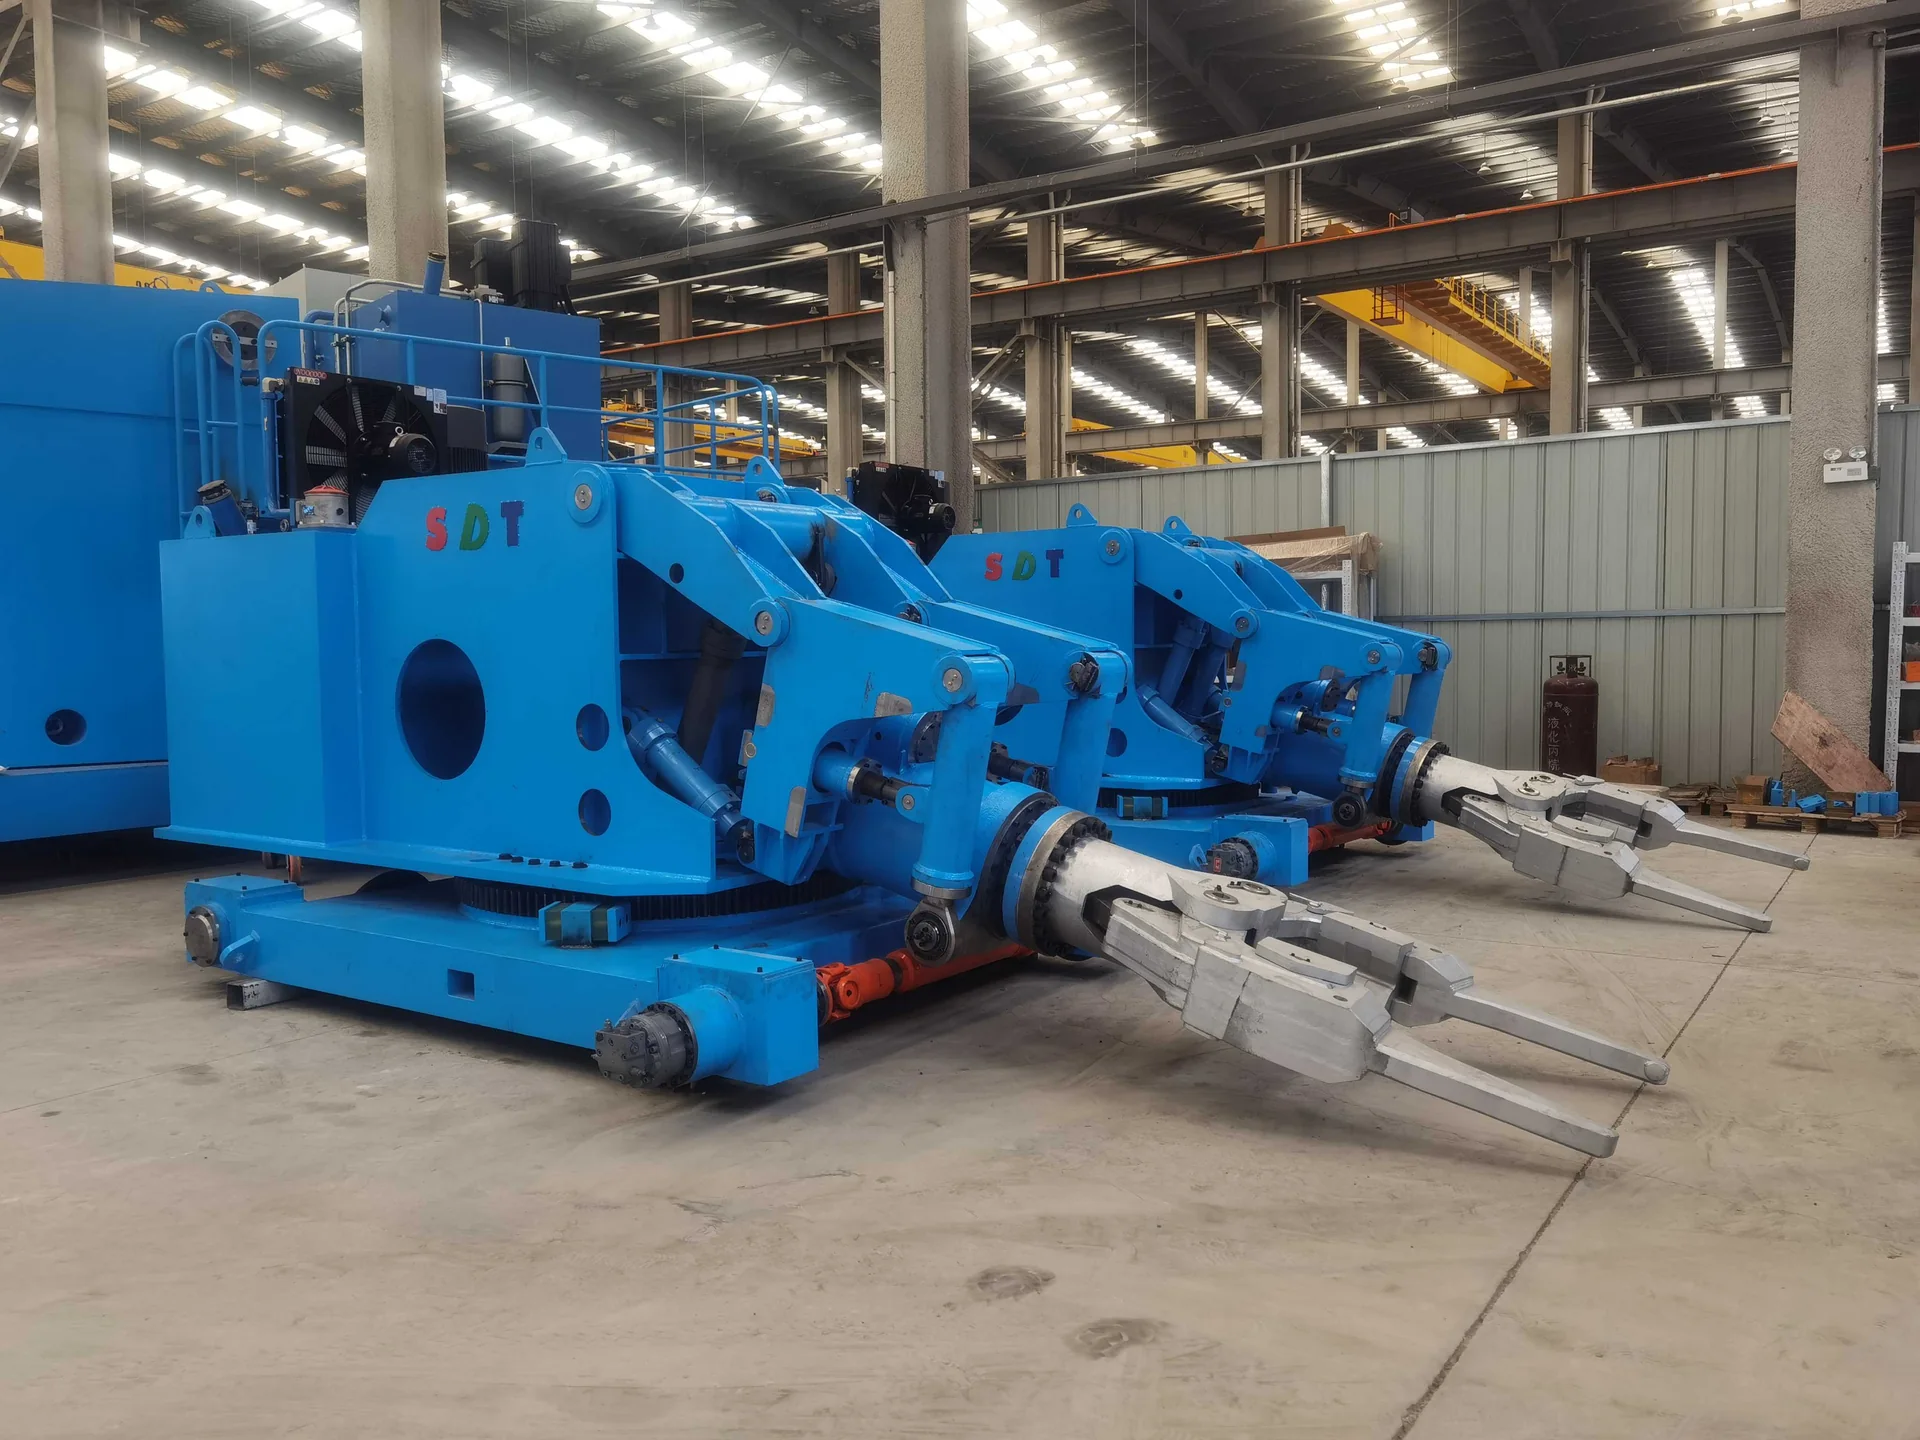
A self-propelled forging manipulator for projects requiring free-driving movement and variable operating positions.
Designed responsibility
Equipment evidence
The mobile direction is selected around floor conditions, turning space, operating visibility, workpiece load moment and the relationship with forging equipment.
Self-propelled movement supports projects with changing operating positions and routes.
The machine is a dedicated forging manipulator—not a forklift-based charging platform.
Travel and workpiece-control actions are engineered around the forging task.
Key references
Floor conditions, turning space, visibility, workpiece geometry and load center remain part of project engineering. Mobile does not mean forklift-based.
Project fit
Four conditions establish the project-specific equipment boundary.
SDT will review the equipment requirement and coordinate the next technical discussion.
Discuss Your Project